ISSN 0439-755X
CN 11-1911/B
CN 11-1911/B
Acta Psychologica Sinica ›› 2026, Vol. 58 ›› Issue (11): 2218-2235.doi: 10.3724/SP.J.1041.2026.2218
Previous Articles Next Articles
XUAN Hongzhou1,2,3, ZHU Jiaying2, LAI Qianen2, HE Guibing2( )
Received:2025-05-10
Published:2026-11-25
Online:2026-09-11
Contact:
Guibing He, E-mail: Supported by:XUAN Hongzhou, ZHU Jiaying, LAI Qianen, HE Guibing. (2026). Dynamic effects of multiround positive and negative feedback from robots and humans on trust and collaboration. Acta Psychologica Sinica, 58(11), 2218-2235.
| Negative feedback | Mean | SD | Positive feedback | Mean | SD |
|---|---|---|---|---|---|
| N?1 | 3.84 | 1.59 | P?1 | 4.81 | 1.49 |
| N?2 | 3.93 | 1.44 | P?2 | 4.70 | 1.37 |
| N?3 | 4.35 | 1.49 | P?3 | 4.48 | 1.40 |
| N?4 | 4.49 | 1.45 | P?4 | 5.19 | 1.46 |
| N?5 | 5.41 | 1.21 | P?5 | 5.46 | 1.38 |
| N?6 | 5.16 | 1.33 | P?6 | 5.10 | 1.29 |
| N?7 | 4.83 | 1.40 | P?7 | 5.04 | 1.38 |
| N?8 | 5.00 | 1.42 | P?8 | 5.42 | 1.34 |
| N?9 | 5.18 | 1.39 | P?9 | 5.76 | 1.42 |
| N?10 | 5.38 | 1.50 | P?10 | 5.82 | 1.34 |
Table 1 Tone-Intensity Ratings of Feedback Statements in the Pilot Experiment
| Negative feedback | Mean | SD | Positive feedback | Mean | SD |
|---|---|---|---|---|---|
| N?1 | 3.84 | 1.59 | P?1 | 4.81 | 1.49 |
| N?2 | 3.93 | 1.44 | P?2 | 4.70 | 1.37 |
| N?3 | 4.35 | 1.49 | P?3 | 4.48 | 1.40 |
| N?4 | 4.49 | 1.45 | P?4 | 5.19 | 1.46 |
| N?5 | 5.41 | 1.21 | P?5 | 5.46 | 1.38 |
| N?6 | 5.16 | 1.33 | P?6 | 5.10 | 1.29 |
| N?7 | 4.83 | 1.40 | P?7 | 5.04 | 1.38 |
| N?8 | 5.00 | 1.42 | P?8 | 5.42 | 1.34 |
| N?9 | 5.18 | 1.39 | P?9 | 5.76 | 1.42 |
| N?10 | 5.38 | 1.50 | P?10 | 5.82 | 1.34 |
| Negative feedback | Positive feedback | ||
|---|---|---|---|
| No. | Statement | No. | Statement |
| N?6 | This result is a little disappointing. You may not have been focused enough. We need to work harder if we want to make the top five. | P?1 | This is already a very good result. I believe you have even greater potential. Let’s work a little harder and make the top five! |
| N?7 | Our performance has not improved much. I think your decisions may have been too casual and not careful enough overall. | P?4 | I think you worked very hard, and I could see you actively making adjustments throughout the process. Keep it up—let’s make one final push. |
| N?8 | We do not have many chances left. You need to take this more seriously and be more attentive, and reflect on the mistakes you may have made earlier. | P?6 | Our scores are fairly close. I believe that if you are a little more careful, our performance will improve to the next level. |
| N?9 | Overall, I do not think you worked hard enough, and your adjustments during the process were inadequate. Your decisions were too casual and not careful enough. | P?7 | We still have a chance. We just need to stay serious and attentive and make a few adjustments to any mistakes we may have made earlier. |
Table 2 Feedback Statements Selected in the Pilot Experiment
| Negative feedback | Positive feedback | ||
|---|---|---|---|
| No. | Statement | No. | Statement |
| N?6 | This result is a little disappointing. You may not have been focused enough. We need to work harder if we want to make the top five. | P?1 | This is already a very good result. I believe you have even greater potential. Let’s work a little harder and make the top five! |
| N?7 | Our performance has not improved much. I think your decisions may have been too casual and not careful enough overall. | P?4 | I think you worked very hard, and I could see you actively making adjustments throughout the process. Keep it up—let’s make one final push. |
| N?8 | We do not have many chances left. You need to take this more seriously and be more attentive, and reflect on the mistakes you may have made earlier. | P?6 | Our scores are fairly close. I believe that if you are a little more careful, our performance will improve to the next level. |
| N?9 | Overall, I do not think you worked hard enough, and your adjustments during the process were inadequate. Your decisions were too casual and not careful enough. | P?7 | We still have a chance. We just need to stay serious and attentive and make a few adjustments to any mistakes we may have made earlier. |
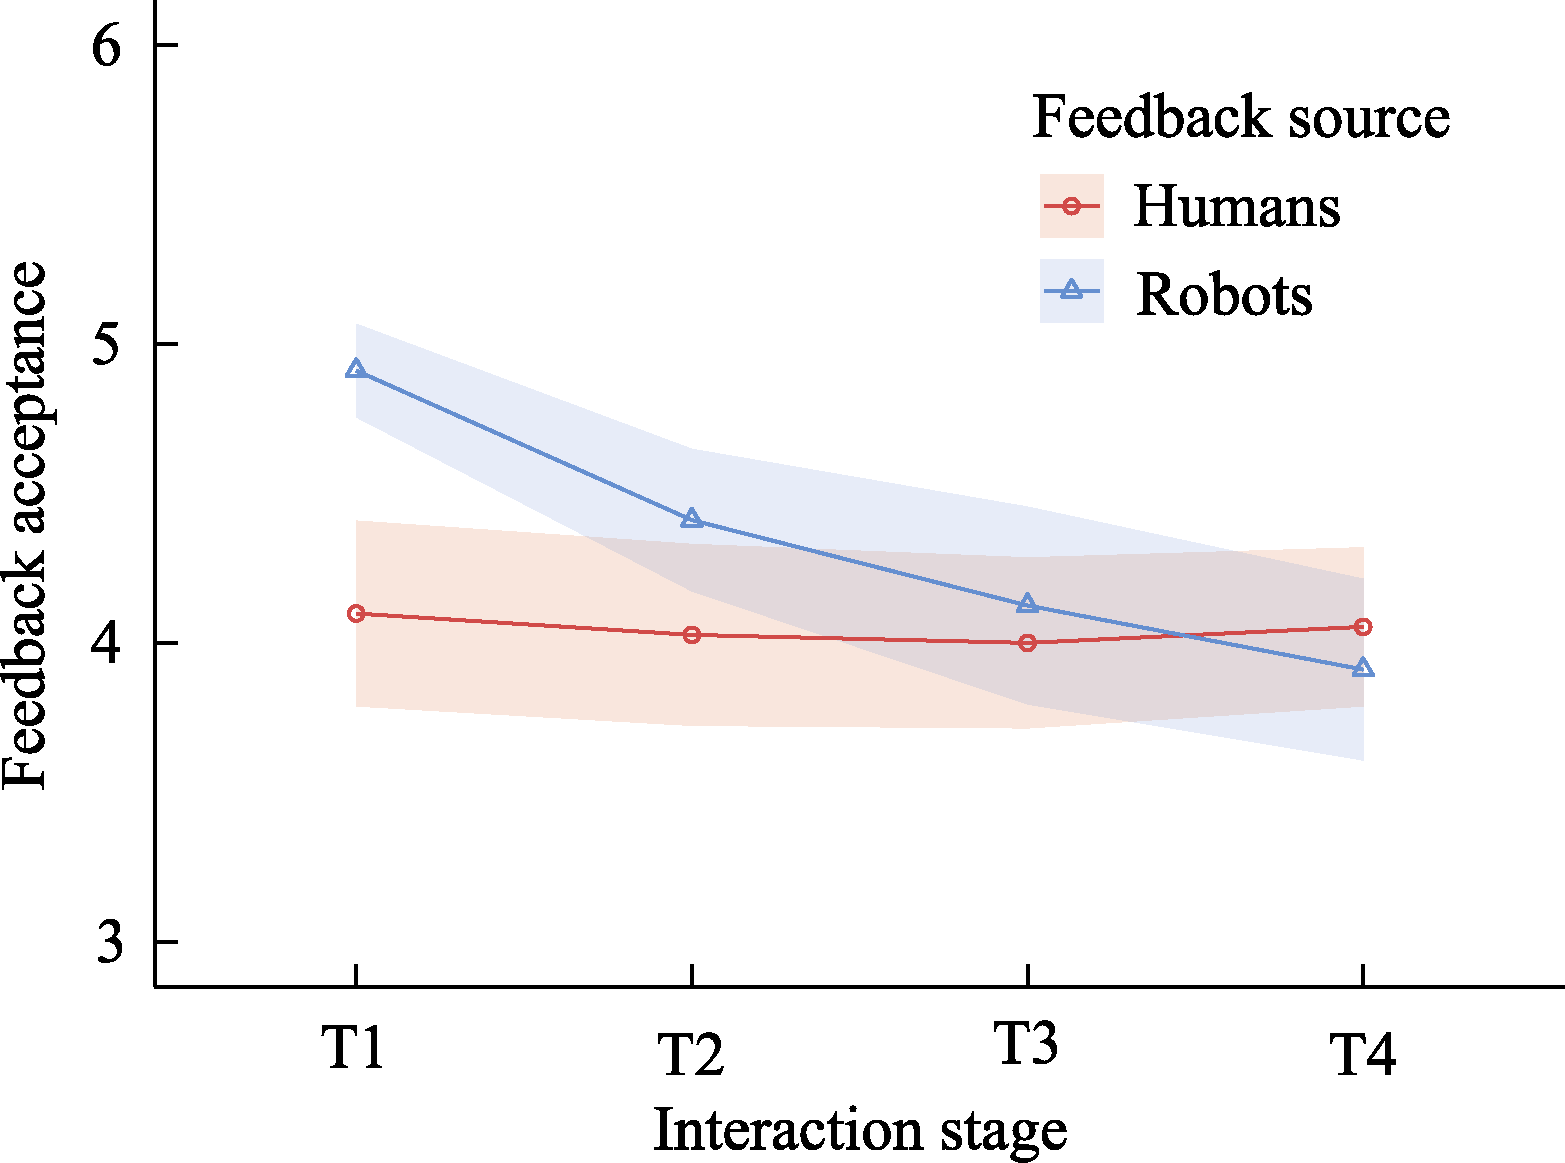
Figure 1. The Pepper Robot and the Experimental Interaction Setting.
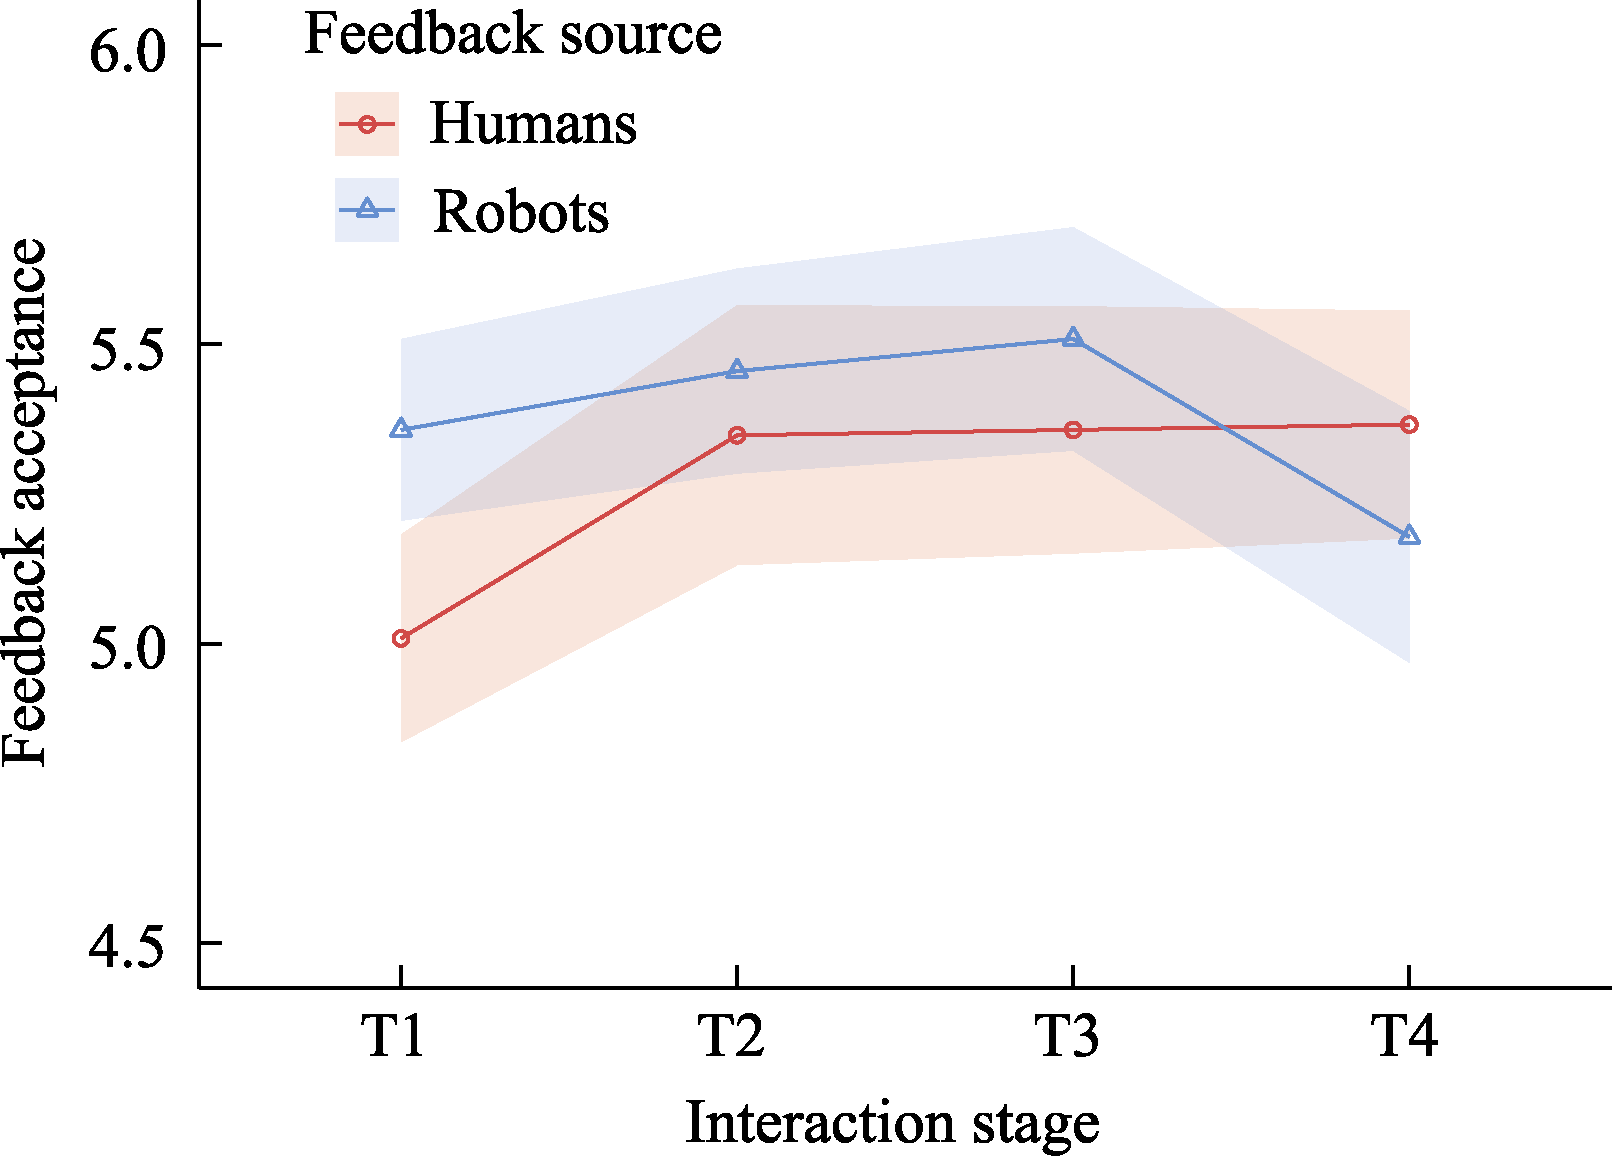
Figure 2. Overall Procedure of Experiment 1.
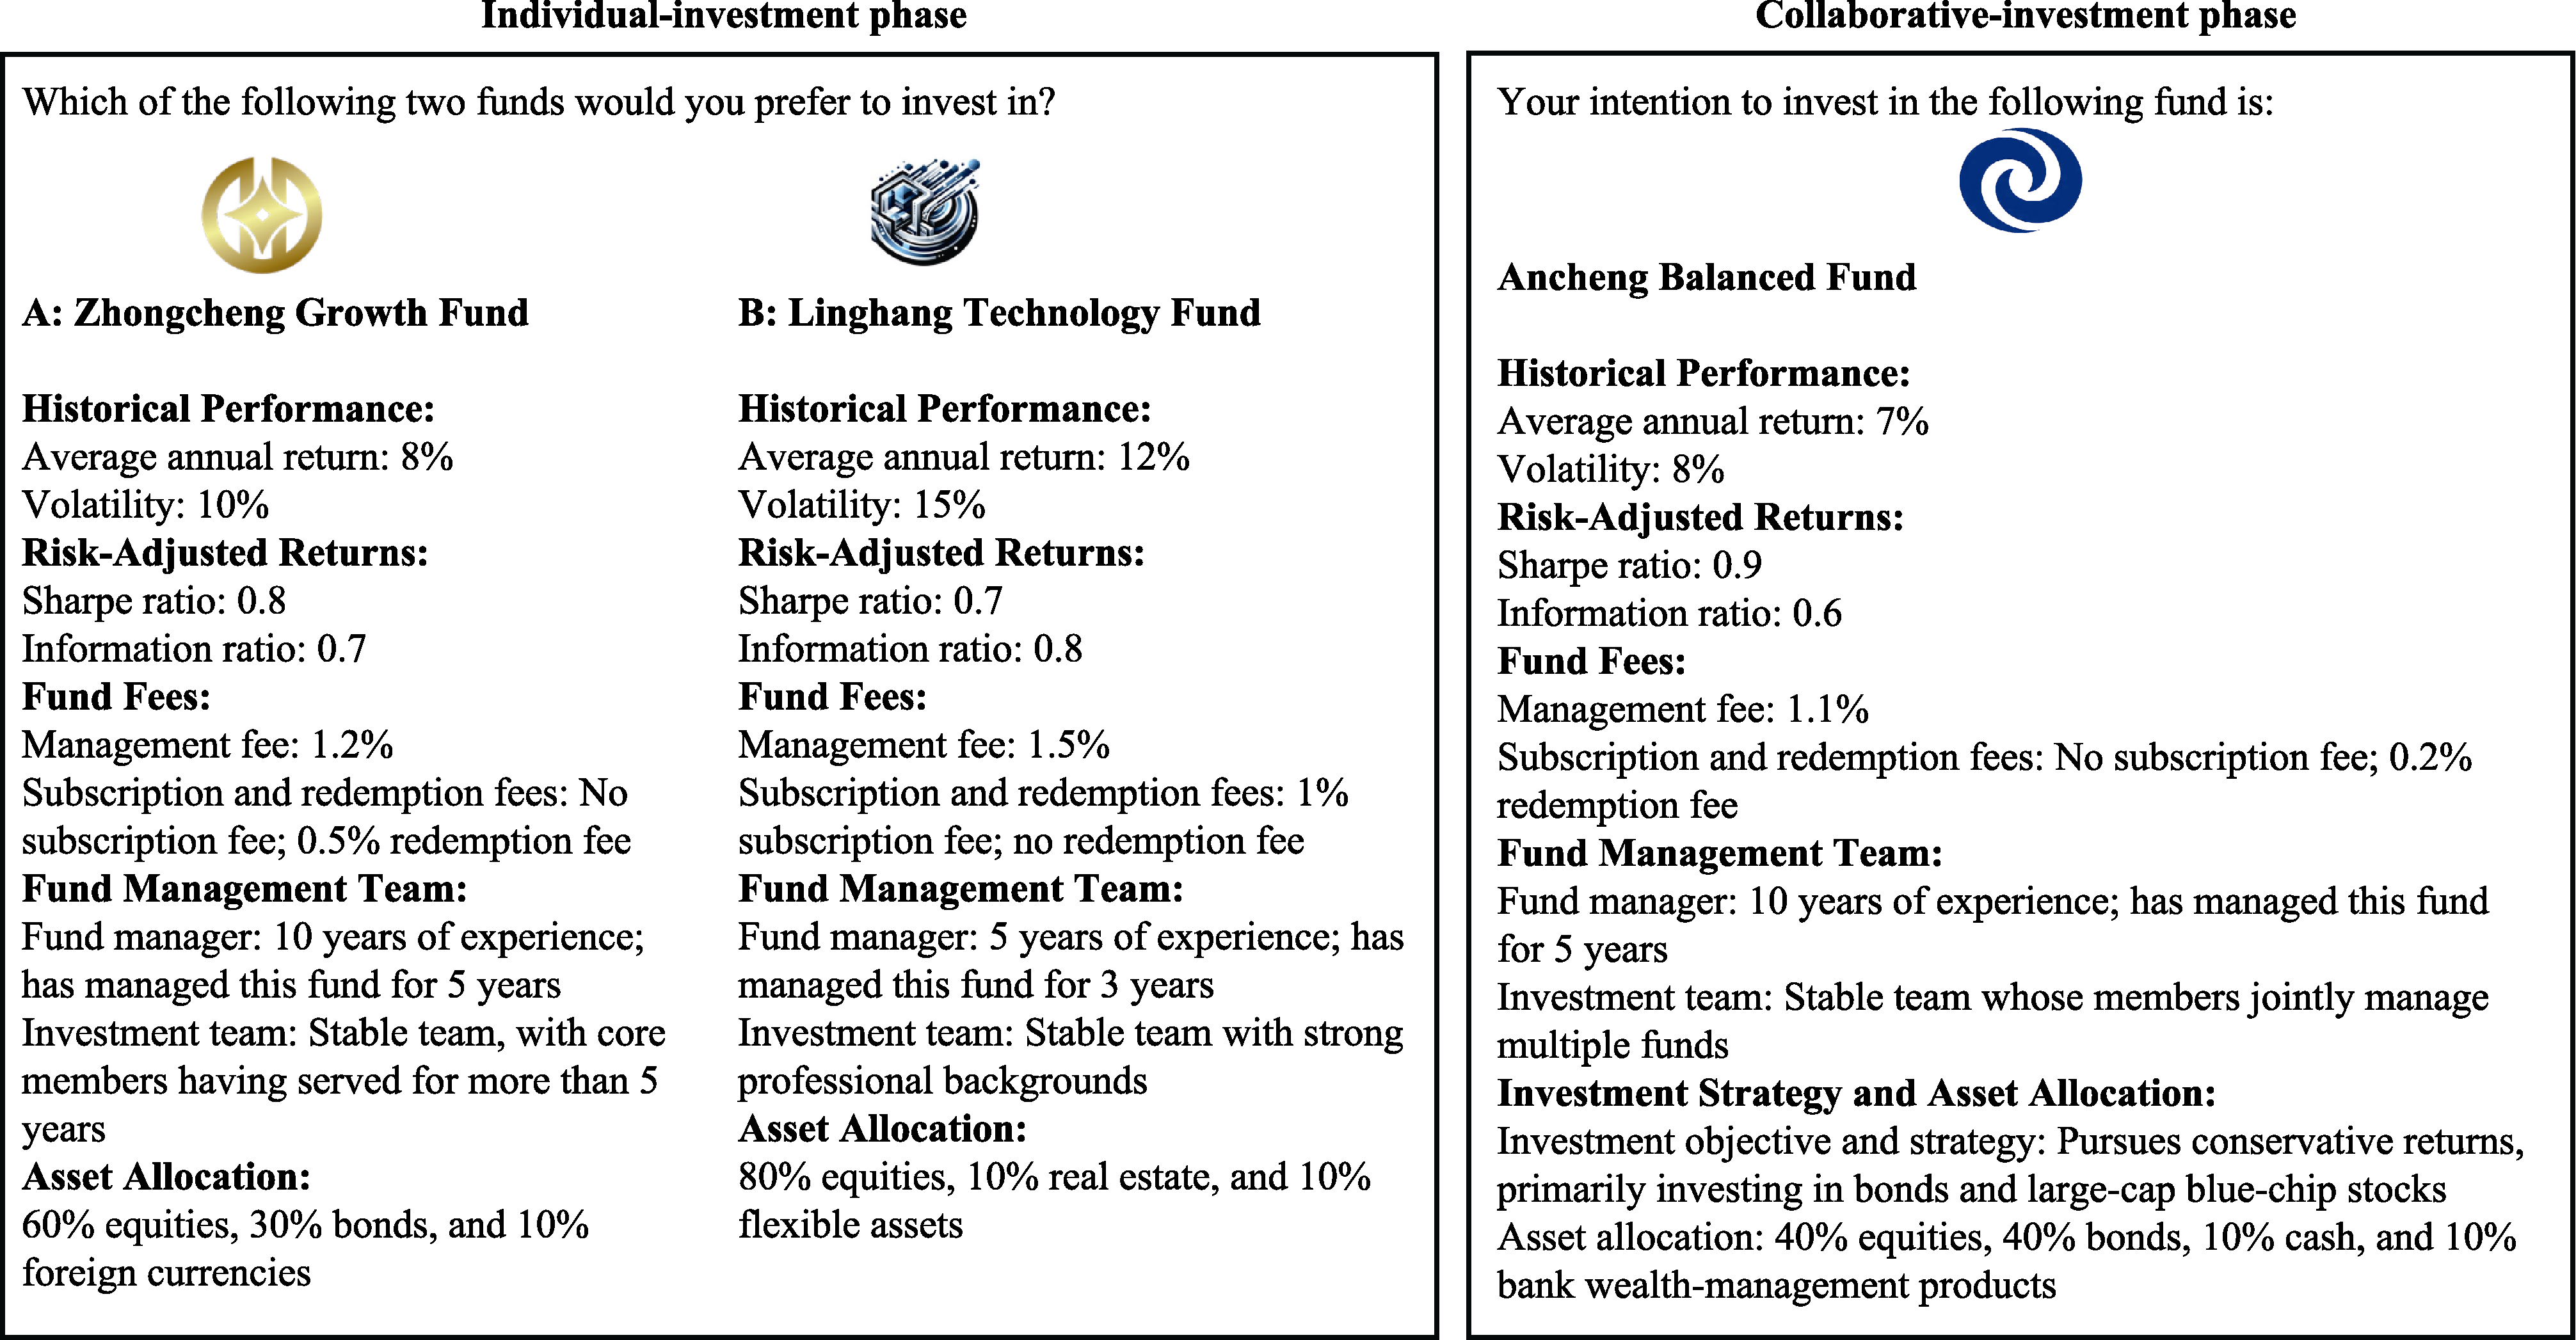
Figure 3. Interfaces for the Individual and Collaborative Investment Tasks.
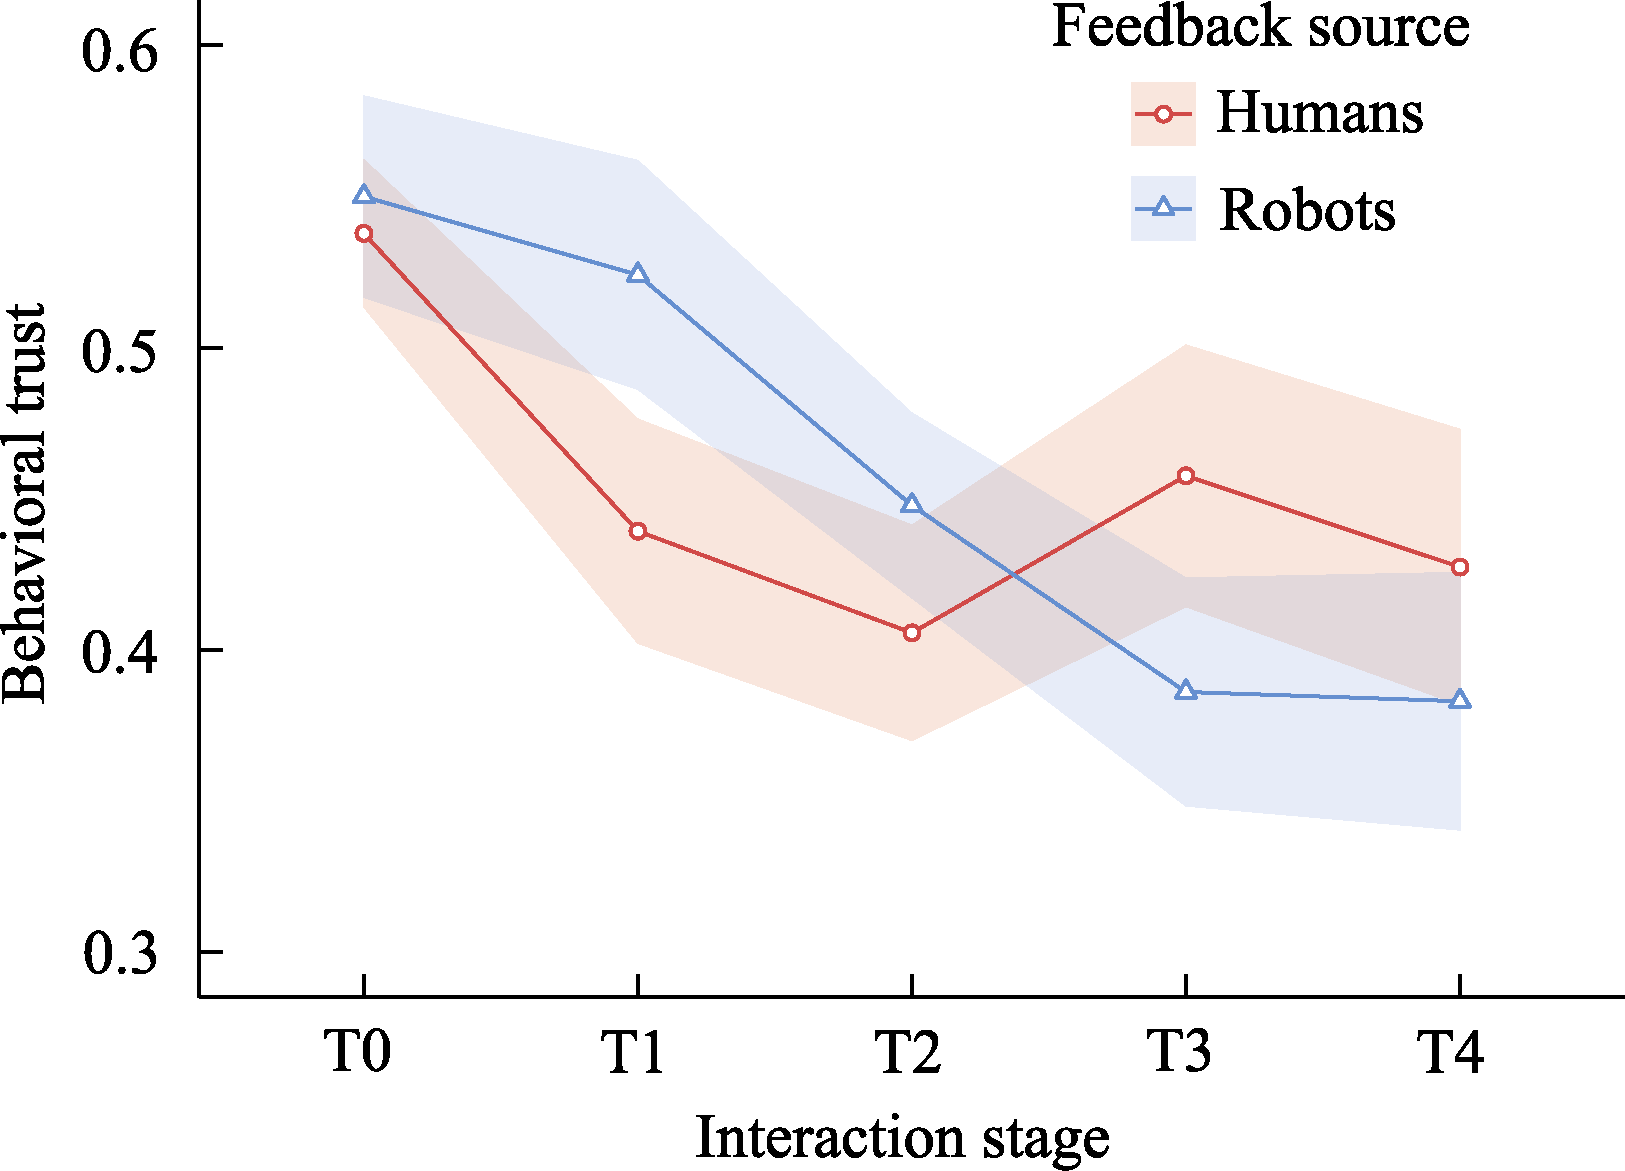
Figure 4. Dynamic Evolution of Behavioral Trust under Multi- round Negative Feedback. Note. Points represent means; shaded bands represent standard errors.
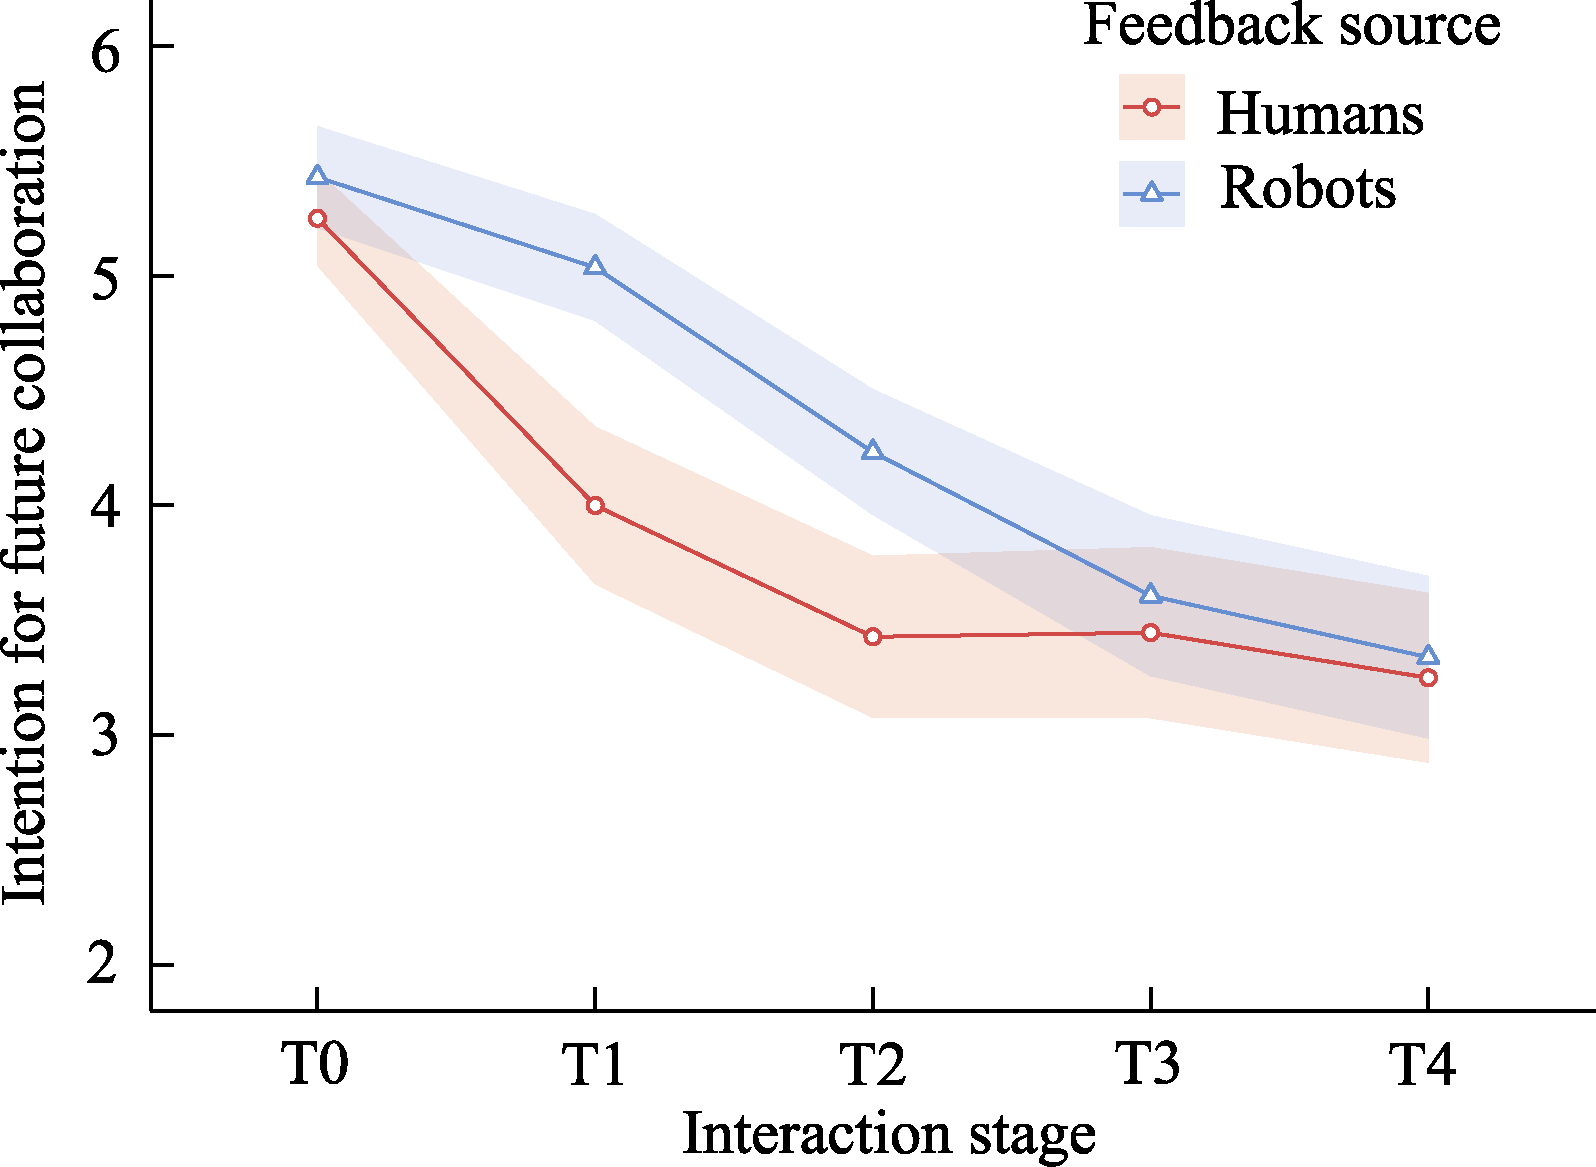
Figure 5. Dynamic Evolution of Intention for Future Collaboration under Multi-round Negative Feedback. Note. Points represent means; shaded bands represent standard errors.
| Stage | Robot condition | Human condition |
|---|---|---|
| T0 | 76.47% | 68.12% |
| T1 | 68.66% | 45.99% |
| T2 | 49.64% | 38.85% |
| T3 | 36.76% | 45.00% |
| T4 | 31.16% | 39.86% |
Table 3 Descriptive Statistics for Advice Adoption in Experiment 1
| Stage | Robot condition | Human condition |
|---|---|---|
| T0 | 76.47% | 68.12% |
| T1 | 68.66% | 45.99% |
| T2 | 49.64% | 38.85% |
| T3 | 36.76% | 45.00% |
| T4 | 31.16% | 39.86% |
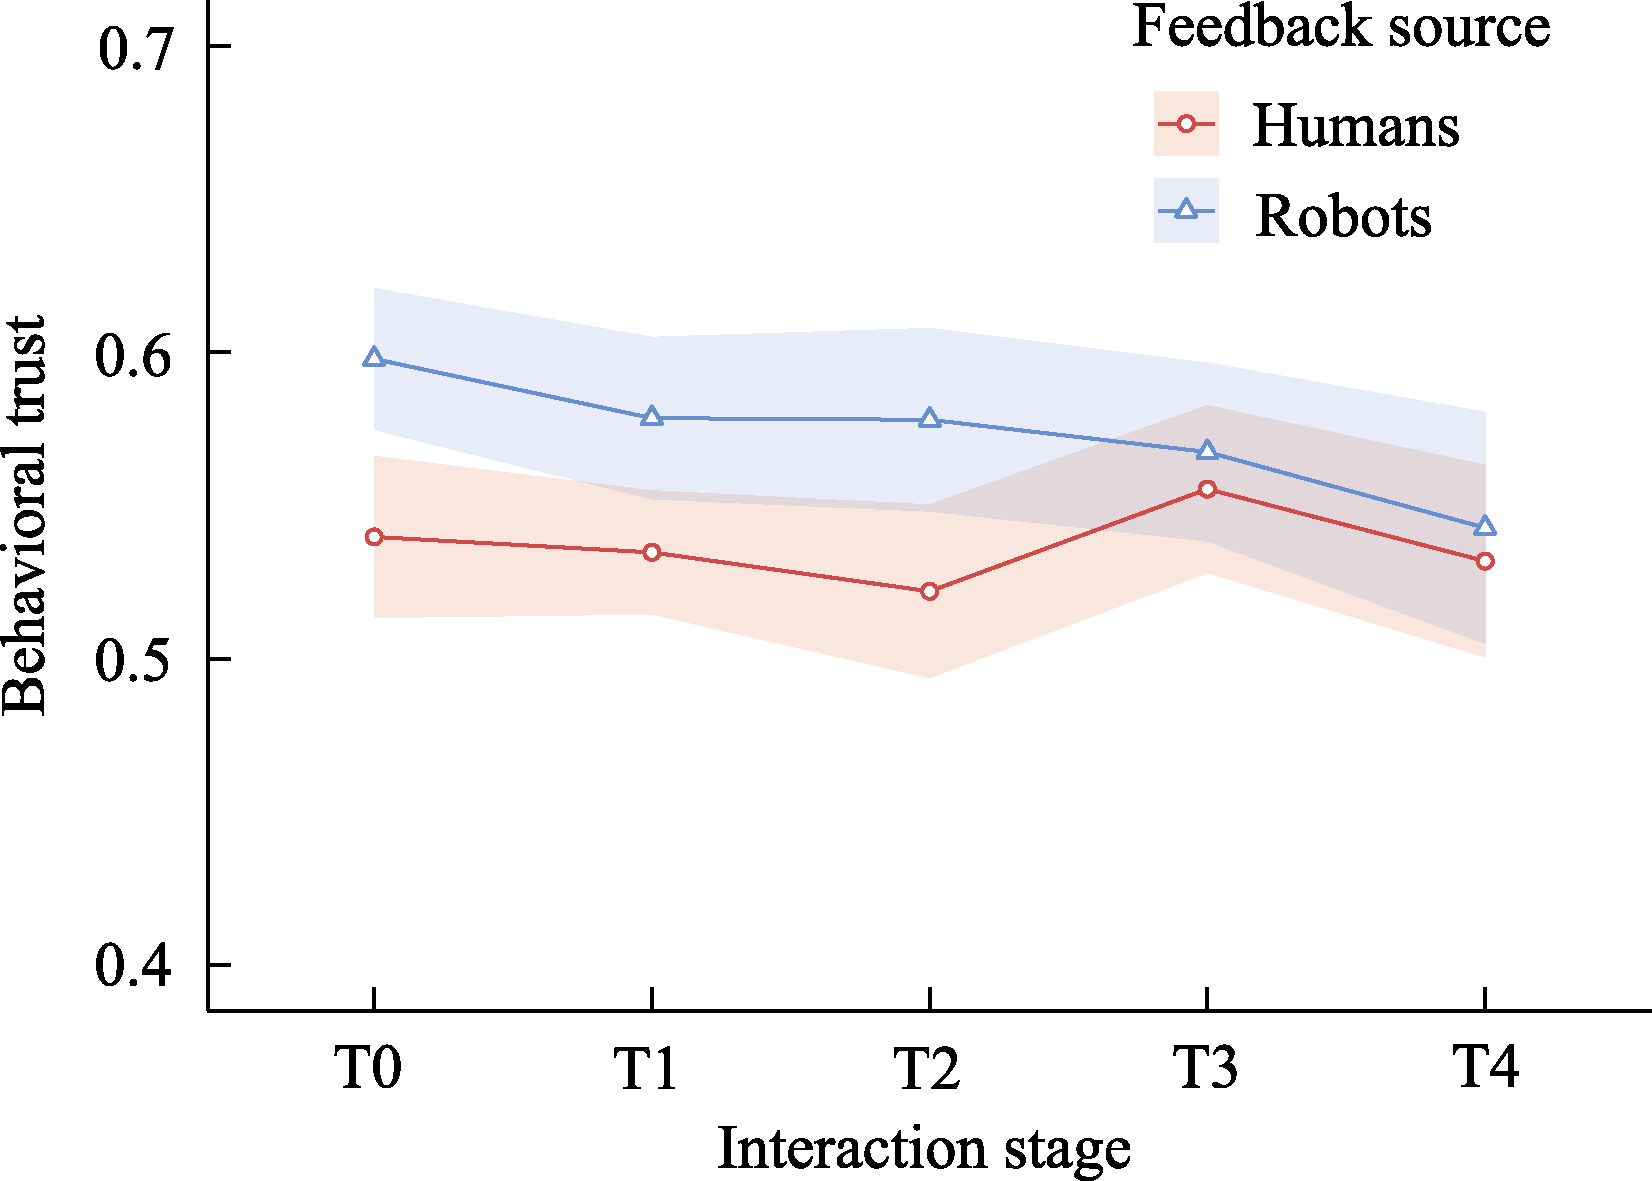
Figure 6. Dynamic Evolution of Behavioral Trust under Multi-round Positive Feedback. Note. Points represent means; shaded bands represent standard errors.
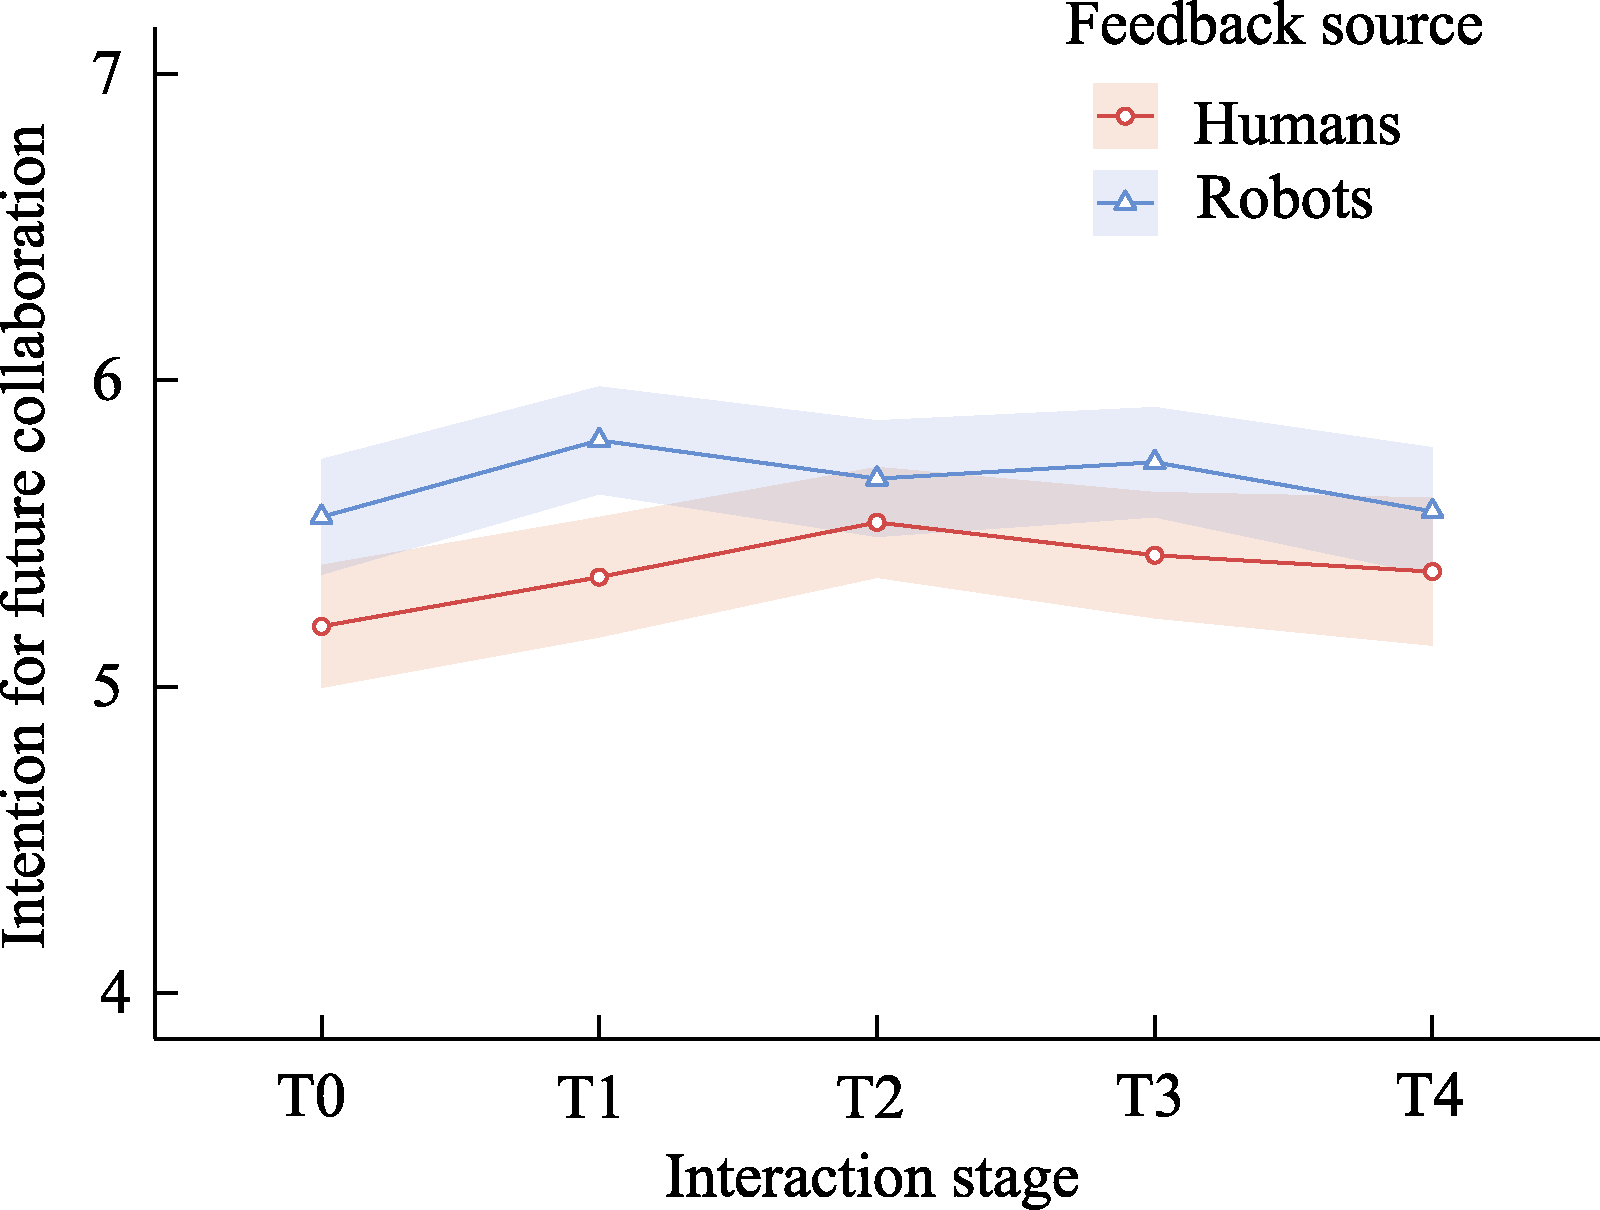
Figure 7. Dynamic Evolution of Intention for Future Collaboration under Multi-round Positive Feedback. Note. Points represent means; shaded bands represent standard errors.
| Stage | Robot condition | Human condition |
|---|---|---|
| T0 | 78.68% | 71.43% |
| T1 | 69.78% | 69.57% |
| T2 | 74.07% | 67.65% |
| T3 | 68.38% | 74.82% |
| T4 | 61.76% | 65.94% |
Table 4 Descriptive Statistics for Advice Adoption in Experiment 2
| Stage | Robot condition | Human condition |
|---|---|---|
| T0 | 78.68% | 71.43% |
| T1 | 69.78% | 69.57% |
| T2 | 74.07% | 67.65% |
| T3 | 68.38% | 74.82% |
| T4 | 61.76% | 65.94% |
| Breakpoint | Behavioral trust | Intention for future collaboration | ||
|---|---|---|---|---|
| AIC | BIC | AIC | BIC | |
| T1 | ?181.33 | ?148.62 | 806.99 | 839.70 |
| T2 | ?179.94 | ?147.23 | 808.95 | 841.67 |
| T3 | ?174.19 | ?141.47 | 826.91 | 859.62 |
Table A1 Comparison of Model Fit (AIC/BIC) for Piecewise Models with Different Breakpoints in Experiment 1
| Breakpoint | Behavioral trust | Intention for future collaboration | ||
|---|---|---|---|---|
| AIC | BIC | AIC | BIC | |
| T1 | ?181.33 | ?148.62 | 806.99 | 839.70 |
| T2 | ?179.94 | ?147.23 | 808.95 | 841.67 |
| T3 | ?174.19 | ?141.47 | 826.91 | 859.62 |
Figure A1. Estimated Marginal Effects of Time on Behavioral Trust by Feedback Source. Note. Curves represent model-predicted marginal means, and shaded areas represent 95% confidence intervals.
Figure A2. Estimated Marginal Effects of Time on Intention for Future Collaboration by Feedback Source. Note. Curves represent model-predicted marginal means, and shaded areas represent 95% confidence intervals.
Figure C1. Dynamic Changes in Feedback Acceptance Across Multiple Rounds of Negative Feedback. Note. Points represent means, and error bands represent standard errors.
Figure C2. Dynamic Changes in Feedback Acceptance Across Multiple Rounds of Positive Feedback. Note. Points represent means, and error bands represent standard errors.
| [1] |
Aazam M., Zeadally S., & Harras K. A. (2018). Deploying fog computing in industrial internet of things and industry 4.0. IEEE Transactions on Industrial Informatics, 14(10), 4674-4682. https://doi.org/10.1109/TII.2018.2855198
doi: 10.1109/TII.2018.2855198 URL |
| [2] |
Abele A. (1985). Thinking about thinking: Causal, evaluative and finalistic cognitions about social situations. European Journal of Social Psychology, 15(3), 315-332. https://doi.org/10.1002/ejsp.2420150306
doi: 10.1002/ejsp.v15:3 URL |
| [3] |
Alarcon G. M., Lyons J. B., Hamdan I. A., & Jessup S. A. (2024). Affective responses to trust violations in a human-autonomy teaming context: Humans versus robots. International Journal of Social Robotics, 16(1), 23-35. https://doi.org/10.1007/s12369-023-01017-w
doi: 10.1007/s12369-023-01017-w URL |
| [4] |
Ali S. A. M., Said N. A., Yunus N. M., Kader, S. F. A., Latif D. S. A., & Munap R. (2014). Hackman and Oldham's job characteristics model to job satisfaction. Procedia - Social and Behavioral Sciences, 129, 46-52. https://doi.org/10.1016/j.sbspro.2014.03.646
doi: 10.1016/j.sbspro.2014.03.646 URL |
| [5] | Aliasghari P., Ghafurian M., Nehaniv C. L., & Dautenhahn K. (2021). Effect of domestic trainee robots’ errors on human teachers’ trust. In 2021 30th IEEE International Conference on Robot and Human Interactive Communication (RO-MAN) (pp.81-88). Vancouver, Canada. https://doi.org/10.1109/RO-MAN50785.2021.9515510 |
| [6] |
Anseel F., & Lievens F. (2006). Certainty as a moderator of feedback reactions? A test of the strength of the self‐verification motive. Journal of Occupational and Organizational Psychology, 79(4), 533-551. https://doi.org/10.1348/096317905X71462
doi: 10.1348/096317905X71462 URL |
| [7] |
Baumeister R. F., Bratslavsky E., Finkenauer C., & Vohs K. D. (2001). Bad is stronger than good. Review of General Psychology, 5(4), 323-370. https://doi.org/10.1037/1089-2680.5.4.323
doi: 10.1037/1089-2680.5.4.323 URL |
| [8] |
Bigman Y. E., & Gray K. (2018). People are averse to machines making moral decisions. Cognition, 181, 21-34. https://doi.org/10.1016/j.cognition.2018.08.003
doi: S0010-0277(18)30208-7 URL pmid: 30107256 |
| [9] | Bracken C. C., Jeffres L. W., & Neuendorf K. A. (2004). Criticism or praise? The impact of verbal versus text-only computer feedback on social presence, intrinsic motivation, and recall. CyberPsychology & Behavior, 7(3), 349-357. https://doi.org/10/c63wgk |
| [10] | Burnham K. P., & Anderson D. R. (2004). Multimodel inference: Understanding AIC and BIC in model selection. Sociological Methods & Research, 33(2), 261-304. https://doi.org/10.1177/0049124104268644 |
| [11] | Candon K., Zhou H., Gillet S., & Vázquez M. (2023). Verbally soliciting human feedback in continuous human-robot collaboration: Effects of the framing and timing of reminders. In Proceedings of the 2023 ACM/IEEE International Conference on Human-Robot Interaction (pp.290-300). Stockholm, Sweden. https://doi.org/10.1145/3568162.3576980 |
| [12] |
Carretié L., Mercado F., Tapia M., & Hinojosa J. A. (2001). Emotion, attention, and the 'negativity bias', studied through event-related potentials. International Journal of Psychophysiology, 41(1), 75-85. https://doi.org/10.1016/S0167-8760(00)00195-1
URL pmid: 11239699 |
| [13] |
Chen N., Cao J., & Hu X. (2024). The effects of robot managers' reward-punishment behaviours on human-robot trust and job performance. International Journal of Social Robotics, 16(3), 529-545. https://doi.org/10.1007/s12369-023-01091-0
doi: 10.1007/s12369-023-01091-0 URL |
| [14] | Chi V. B., & Malle B. F. (2023). People dynamically update trust when interactively teaching robots. In Proceedings of the 2023 ACM/IEEE International Conference on Human-Robot Interaction (pp.554-564). Stockholm, Sweden. https://doi.org/10.1145/3568162.3576962 |
| [15] | Cho J. H., Chan K., & Adali S. (2015). A survey on trust modeling. ACM Computing Surveys (CSUR), 48(2), 1-40. https://doi.org/10.1145/2815595 |
| [16] | Christoffersen K., & Woods D. (2002). How to make automated systems team players. Advances in Human Performance and Cognitive Engineering Research, 2, 1-12. https://doi.org/10.1016/S1479-3601(02)02003-9 |
| [17] |
Costa A. C. (2003). Work team trust and effectiveness. Personnel Review, 32(5), 605-622. https://doi.org/10.1108/00483480310488360
doi: 10.1108/00483480310488360 URL |
| [18] |
Czaja S. J., Charness N., Fisk A. D., Hertzog C., Nair S. N., Rogers W. A., & Sharit J. (2006). Factors predicting the use of technology: Findings from the Center for Research and Education on Aging and Technology Enhancement (CREATE). Psychology and Aging, 21(2), 333-352. https://doi.org/10.1037/0882-7974.21.2.333
doi: 10.1037/0882-7974.21.2.333 URL pmid: 16768579 |
| [19] |
Damen N., & Toh C. (2019). Designing for trust: Understanding the role of agent gender and location on user perceptions of trust in home automation. Journal of Mechanical Design, 141(6), 061101. https://doi.org/10.1115/1.4042223
doi: 10.1115/1.4042223 URL |
| [20] |
De Freitas J., Agarwal S., Schmitt B., & Haslam N. (2023). Psychological factors underlying attitudes toward AI tools. Nature Human Behaviour, 7(11), 1845-1854. https://doi.org/10.1038/s41562-023-01734-2
doi: 10.1038/s41562-023-01734-2 URL pmid: 37985913 |
| [21] |
De Visser E. J., Monfort S. S., McKendrick R., Smith M. A. B., McKnight P. E., Krueger F., & Parasuraman R. (2016). Almost human: Anthropomorphism increases trust resilience in cognitive agents. Journal of Experimental Psychology: Applied, 22(3), 331-349. https://doi.org/10.1037/xap0000092
doi: 10.1037/xap0000092 URL |
| [22] | De Visser E. J., Pak R., & Neerincx M. A. (2017). Trust development and repair in human-robot teams. In Proceedings of the Companion of the 2017 ACM/IEEE International Conference on Human-Robot Interaction (pp.103-104). Vienna, Austria. https://doi.org/10.1145/3029798.3038409 |
| [23] |
De Visser E. J., Peeters, M. M. M., Jung M. F., Kohn S., Shaw T. H., Pak R., & Neerincx M. A. (2020). Towards a theory of longitudinal trust calibration in human-robot teams. International Journal of Social Robotics, 12(2), 459-478. https://doi.org/10.1007/s12369-019-00596-x
doi: 10.1007/s12369-019-00596-x URL |
| [24] |
Deepa R., Sekar S., Malik A., Kumar J., & Attri R. (2024). Impact of AI-focussed technologies on social and technical competencies for HR managers - A systematic review and research agenda. Technological Forecasting and Social Change, 202, 123301. https://doi.org/10.1016/j.techfore.2024.123301
doi: 10.1016/j.techfore.2024.123301 URL |
| [25] |
DeRosa D. M., Hantula D. A., Kock N., & D’Arcy J. (2004). Trust and leadership in virtual teamwork: A media naturalness perspective. Human Resource Management, 43(2-3), 219-232. https://doi.org/10.1002/hrm.20016
doi: 10.1002/hrm.v43:2/3 URL |
| [26] |
Desmet P. T. M., De Cremer D., & Van Dijk E. (2011). Trust recovery following voluntary or forced financial compensations in the trust game: The role of trait forgiveness. Personality and Individual Differences, 51(3), 267-273. https://doi.org/10.1016/j.paid.2010.05.027
doi: 10.1016/j.paid.2010.05.027 URL |
| [27] |
Dirks K. T., Kim P. H., Ferrin D. L., & Cooper C. D. (2011). Understanding the effects of substantive responses on trust following a transgression. Organizational Behavior and Human Decision Processes, 114(2), 87-103. https://doi.org/10.1016/j.obhdp.2010.10.003
doi: 10.1016/j.obhdp.2010.10.003 URL |
| [28] |
Djamasbi S., & Loiacono E. T. (2008). Do men and women use feedback provided by their decision support systems (DSS) differently? Decision Support Systems, 44(4), 854-869. https://doi.org/10.1016/j.dss.2007.10.008
doi: 10.1016/j.dss.2007.10.008 URL |
| [29] |
Dzindolet M. T., Pierce L. G., Beck H. P., & Dawe L. A. (2002). The perceived utility of human and automated aids in a visual detection task. Human Factors, 44(1), 79-94. https://doi.org/10.1518/0018720024494856
URL pmid: 12118875 |
| [30] | Fousiani K. (2020). Power asymmetry, negotiations and conflict management in organizations. Organizational conflict—New insights. IntechOpen. https://doi.org/10.5772/intechopen.95492 |
| [31] |
Frey C. B., & Osborne M. A. (2017). The future of employment: How susceptible are jobs to computerisation? Technological Forecasting and Social Change, 114, 254-280. https://doi.org/10.1016/j.techfore.2016.08.019
doi: 10.1016/j.techfore.2016.08.019 URL |
| [32] |
Fulmer C. A., & Gelfand M. J. (2012). At what level (and in whom) we trust: Trust across multiple organizational levels. Journal of Management, 38(4), 1167-1230. https://doi.org/10.2139/ssrn.1873149
doi: 10.1177/0149206312439327 URL |
| [33] |
Getha-Taylor H., Grayer M. J., Kempf R. J., & O’Leary R. (2019). Collaborating in the absence of trust? What collaborative governance theory and practice can learn from the literatures of conflict resolution, psychology, and law. The American Review of Public Administration, 49(1), 51-64. https://doi.org/10.1177/0275074018773089
doi: 10.1177/0275074018773089 URL |
| [34] |
Gkinko L., & Elbanna A. (2023). Designing trust: The formation of employees' trust in conversational AI in the digital workplace. Journal of Business Research, 158, 113707. https://doi.org/10.1016/j.jbusres.2023.113707
doi: 10.1016/j.jbusres.2023.113707 URL |
| [35] |
Glikson E., & Woolley A. W. (2020). Human trust in artificial intelligence: Review of empirical research. Academy of Management Annals, 14(2), 627-660. https://doi.org/10.5465/annals.2018.0057
doi: 10.5465/annals.2018.0057 URL |
| [36] |
Gray H. M., Gray K., & Wegner D. M. (2007). Dimensions of mind perception. Science, 315(5812), 619. https://doi.org/10.1126/science.1134475
doi: 10.1126/science.1134475 URL |
| [37] | Groom V., Chen J., Johnson T., Kara F. A., & Nass C. (2010). Critic, compatriot, or chump?: Responses to robot blame attribution. In 2010 5th ACM/IEEE International Conference on Human-Robot Interaction (HRI) (pp. 211-217). Osaka, Japan. https://doi.org/10.1109/HRI.2010.5453192 |
| [38] |
Gross J., Leib M., Offerman T., & Shalvi S. (2018). Ethical free riding: When honest people find dishonest partners. Psychological Science, 29(12), 1956-1968. https://doi.org/10.1177/0956797618796480
doi: 10.1177/0956797618796480 URL pmid: 30325707 |
| [39] |
Grossman R., & Feitosa J. (2018). Team trust over time: Modeling reciprocal and contextual influences in action teams. Human Resource Management Review, 28(4), 395-410. https://doi.org/10.1016/j.hrmr.2017.03.006
doi: 10.1016/j.hrmr.2017.03.006 URL |
| [40] | Guan J., Li W. P., He G. H., & Zhang X. A. (2025). Artificial intelligence feedback: Literature review and research prospects. Foreign Economics & Management, 47(3), 83-100. https://doi.org/10.16538/j.cnki.fem.20240622.301 |
| [41] |
Habbal A., Ali M. K., & Abuzaraida M. A. (2024). Artificial intelligence trust, risk and security management (AI trism): Frameworks, applications, challenges and future research directions. Expert Systems with Applications, 240, 122442. https://doi.org/10.1016/j.eswa.2023.122442
doi: 10.1016/j.eswa.2023.122442 URL |
| [42] |
Haenlein M., & Kaplan A. (2021). Artificial intelligence and robotics: Shaking up the business world and society at large. Journal of Business Research, 124, 405-407. https://doi.org/10.1016/j.jbusres.2020.10.042
doi: 10.1016/j.jbusres.2020.10.042 URL |
| [43] |
Hancock P. A., Billings D. R., Schaefer K. E., Chen J. Y. C., de Visser E. J., & Parasuraman R. (2011). A meta-analysis of factors affecting trust in human-robot interaction. Human Factors, 53(5), 517-527. https://doi.org/10.1177/0018720811417254
URL pmid: 22046724 |
| [44] |
He G. B., Chen C., He Z. T., Cui L. D., Lu J. Q., Xuan H. Z., & Lin L. (2022). Human-agent collaborative decision-making in intelligent organizations: A perspective of human-agent inner compatibility. Advances in Psychological Science, 30(12), 2619-2627.
doi: 10.3724/SP.J.1042.2022.02619 |
| [45] |
Hecklau F., Galeitzke M., Flachs S., & Kohl H. (2016). Holistic approach for human resource management in Industry 4.0. Procedia CIRP, 54, 1-6. https://doi.org/10.1016/j.procir.2016.05.102
doi: 10.1016/j.procir.2016.05.102 URL |
| [46] |
Hicks L. J., Smith A. C., Ralph B. C. W., & Smilek D. (2020). Restoration of sustained attention following virtual nature exposure: Undeniable or unreliable? Journal of Environmental Psychology, 71, 101488. https://doi.org/10.1016/j.jenvp.2020.101488
doi: 10.1016/j.jenvp.2020.101488 URL |
| [47] |
Higgins R., Hartley P., & Skelton A. (2001). Getting the message across: The problem of communicating assessment feedback. Teaching in Higher Education, 6(2), 269-274. https://doi.org/10.1080/13562510120045230
doi: 10.1080/13562510120045230 URL |
| [48] |
Hoff K. A., & Bashir M. (2015). Trust in automation: Integrating empirical evidence on factors that influence trust. Human Factors, 57(3), 407-434. https://doi.org/10.1177/0018720814547570
doi: 10.1177/0018720814547570 URL pmid: 25875432 |
| [49] |
Huang H., & Rau P. L. P. (2024). How to provide feedback? The role of robot's language and feedback framework. International Journal of Human-Computer Interaction, 40(8), 1856-1872. https://doi.org/10.1080/10447318.2023.2223946
doi: 10.1080/10447318.2023.2223946 URL |
| [50] |
Hutchinson J., Strickland L., Farrell S., & Loft S. (2023). The perception of automation reliability and acceptance of automated advice. Human Factors, 65(8), 1596-1612. https://doi.org/10.1177/00187208211062985
doi: 10.1177/00187208211062985 URL |
| [51] |
Ito T. A., Larsen J. T., Smith N. K., & Cacioppo J. T. (1998). Negative information weighs more heavily on the brain: The negativity bias in evaluative categorizations. Journal of Personality and Social Psychology, 75(4), 887-900. https://doi.org/10.1037/0022-3514.75.4.887
doi: 10.1037//0022-3514.75.4.887 URL pmid: 9825526 |
| [52] |
Jawahar I. M. (2006). Correlates of satisfaction with performance appraisal feedback. Journal of Labor Research, 27(2), 213-236. https://doi.org/10.1007/s12122-006-1004-1
doi: 10.1007/s12122-006-1004-1 URL |
| [53] |
Jones G. R., & George J. M. (1998). The experience and evolution of trust: Implications for cooperation and teamwork. Academy of Management Review, 23(3), 531-546. https://doi.org/10.5465/amr.1998.926625
doi: 10.2307/259293 URL |
| [54] |
Kaplan A. D., Kessler T. T., Brill J. C., & Hancock P. A. (2023). Trust in artificial intelligence: Meta-analytic findings. Human Factors, 65(2), 337-359. https://doi.org/10.1177/00187208211013988
doi: 10.1177/00187208211013988 URL |
| [55] | Khavas, Z. R., Ahmadzadeh S. R., & Robinette P. (2020). Modeling trust in human-robot interaction:A survey. In A. R. Wagner, D. Feil-Seifer, K. S. Haring, S. Rossi, T. Williams, H. He, & S. S, Ge (Eds.), International Conference on Social Robotics (pp. 529-541). Springer International Publishing. https://doi.org/10.1007/978-3-030-62056-1_44 |
| [56] |
Kinicki A. J., Prussia G. E., Wu B. J., & McKee-Ryan F. M. (2004). A covariance structure analysis of employees' response to performance feedback. Journal of Applied Psychology, 89(6), 1057-1069. https://doi.org/10.1037/0021-9010.89.6.1057
URL pmid: 15584841 |
| [57] |
Komiak S. Y., & Benbasat I. (2006). The effects of personalization and familiarity on trust and adoption of recommendation agents. MIS Quarterly, 30(4), 941-960. https://doi.org/10.2307/25148760
doi: 10.2307/25148760 URL |
| [58] |
Kopp T., Baumgartner M., & Kinkel S. (2023). "It's not Paul, it's a robot": The impact of linguistic framing and the evolution of trust and distrust in a collaborative robot during a human-robot interaction. International Journal of Human-Computer Studies, 178, 103095. https://doi.org/10.1016/j.ijhcs.2023.103095
doi: 10.1016/j.ijhcs.2023.103095 URL |
| [59] |
Korsgaard M. A., Kautz J., Bliese P., Samson K., & Kostyszyn P. (2018). Conceptualising time as a level of analysis: New directions in the analysis of trust dynamics. Journal of Trust Research, 8(2), 142-165. https://doi.org/10.1080/21515581.2018.1516557
doi: 10.1080/21515581.2018.1516557 URL |
| [60] |
Kożuch B., & Sienkiewicz-Małyjurek K. (2022). Building collaborative trust in public safety networks. Safety Science, 152, 105785. https://doi.org/10.1016/j.ssci.2022.105785
doi: 10.1016/j.ssci.2022.105785 URL |
| [61] |
Kraus J., Scholz D., Stiegemeier D., & Baumann M. (2020). The more you know: Trust dynamics and calibration in highly automated driving and the effects of take-overs, system malfunction, and system transparency. Human Factors, 62(5), 718-736. https:// doi.org/10.1177/0018720819853686
doi: 10.1177/0018720819853686 URL pmid: 31233695 |
| [62] |
Kuhnen C. M., & Tymula A. (2012). Feedback, self-esteem, and performance in organizations. Management Science, 58(1), 94-113. https://doi.org/10.1287/mnsc.1110.1379
doi: 10.1287/mnsc.1110.1379 URL |
| [63] | Kulms, P., & Kopp S. (2016). The effect of embodiment and competence on trust and cooperation in human-agent interaction. In D. Traum, W. Swartout, P. Khooshabeh, S. Kopp, S. Scherer, & A. Leuski (Eds.), Intelligent Virtual Agents: 16th International Conference (pp. 75-84). Springer International Publishing. https://doi.org/10.1007/978-3-319-47665-0_7 |
| [64] | Kulms, P., & Kopp S. (2019). More human-likeness, more trust? The effect of anthropomorphism on self-reported and behavioral trust in continued and interdependent human-agent cooperation. In F. Alt, A. Bulling, & T. Döring (Eds.), Proceedings of Mensch und Computer 2019 (pp.31-42). Hamburg, Germany. https://doi.org/10.1145/3340764.3340793 |
| [65] |
Kuvaas B. (2006). Performance appraisal satisfaction and employee outcomes: Mediating and moderating roles of work motivation. The International Journal of Human Resource Management, 17(3), 504-522. https://doi.org/10.1080/09585190500521581
doi: 10.1080/09585190500521581 URL |
| [66] |
Lanz L., Briker R., & Gerpott F. H. (2024). Employees adhere more to unethical instructions from human than AI supervisors: Complementing experimental evidence with machine learning. Journal of Business Ethics, 189(3), 625-646. https://doi.org/10.1007/s10551-023-05393-1
doi: 10.1007/s10551-023-05393-1 URL |
| [67] |
Lee D., Stajkovic A. D., & Cho B. (2011). Interpersonal trust and emotion as antecedents of cooperation: Evidence from korea. Journal of Applied Social Psychology, 41(7), 1603-1631. https://doi.org/10.1111/j.1559-1816.2011.00776.x
doi: 10.1111/jasp.2011.41.issue-7 URL |
| [68] |
Lee J. D., & See K. A. (2004). Trust in automation: Designing for appropriate reliance. Human Factors, 46(1), 50-80. https://doi.org/10.1518/hfes.46.1.50_30392
doi: 10.1518/hfes.46.1.50_30392 URL pmid: 15151155 |
| [69] | Lee M. K. (2018). Understanding perception of algorithmic decisions: Fairness, trust, and emotion in response to algorithmic management. Big Data & Society, 5(1), 2053951718756684. https://doi.org/10.1177/2053951718756684 |
| [70] |
Leung K., Su S., & Morris M. W. (2001). When is criticism not constructive? The roles of fairness perceptions and dispositional attributions in employee acceptance of critical supervisory feedback. Human Relations, 54(9), 1155-1187. https://doi.org/10.1177/0018726701549002
doi: 10.1177/0018726701549002 URL |
| [71] |
Lewandowsky S., Mundy M., & Tan G. P. A. (2000). The dynamics of trust: Comparing humans to automation. Journal of Experimental Psychology: Applied, 6(2), 104-123. https://doi.org/10.1037/1076-898X.6.2.104
doi: 10.1037/1076-898X.6.2.104 URL |
| [72] |
Lewis J. D., & Weigert A. (1985). Trust as a social reality. Social Forces, 63(4), 967-985. https://doi.org/10.1093/sf/63.4.967
doi: 10.2307/2578601 URL |
| [73] |
Li J.-M., Zhang R.-X., Wu T.-J., & Mao M. (2024). How does work autonomy in human-robot collaboration affect hotel employees’ work and health outcomes? Role of job insecurity and person-job fit. International Journal of Hospitality Management, 117, 103654. https://doi.org/10.1016/j.ijhm.2023.103654
doi: 10.1016/j.ijhm.2023.103654 URL |
| [74] |
Logg J. M., Minson J. A., & Moore D. A. (2019). Algorithm appreciation: People prefer algorithmic to human judgment. Organizational Behavior and Human Decision Processes, 151, 90-103. https://doi.org/10.1016/j.obhdp.2018.12.005
doi: 10.1016/j.obhdp.2018.12.005 URL |
| [75] |
Luo R., Du N., & Yang X. J. (2022). Evaluating effects of enhanced autonomy transparency on trust, dependence, and human-autonomy team performance over time. International Journal of Human- Computer Interaction, 38(18-20), 1962-1971. https://doi.org/10.1080/10447318.2022.2097602
doi: 10.1080/10447318.2022.2097602 URL |
| [76] |
Lv X., Shi K., He Y., Ji Y., & Lan T. (2024). My colleague is not "human": Will working with robots make you act more indifferently? Journal of Business Research, 176, 114585. https://doi.org/10.1016/j.jbusres.2024.114585
doi: 10.1016/j.jbusres.2024.114585 URL |
| [77] |
Madhavan P., & Wiegmann D. A. (2007). Similarities and differences between human-human and human-automation trust: An integrative review. Theoretical Issues in Ergonomics Science, 8(4), 277-301. https://doi.org/10/d4sv4f
doi: 10.1080/14639220500337708 URL |
| [78] |
Malik A., Budhwar P., & Kazmi B. A. (2023). Artificial intelligence (AI)-assisted HRM: Towards an extended strategic framework. Human Resource Management Review, 33(1), 100940. https://doi.org/10.1016/j.hrmr.2022.100940
doi: 10.1016/j.hrmr.2022.100940 URL |
| [79] |
Malle B. F., Guglielmo S., & Monroe A. E. (2014). A theory of blame. Psychological Inquiry, 25(2), 147-186. https://doi.org/10.1080/1047840X.2014.877340
doi: 10.1080/1047840X.2014.877340 URL |
| [80] |
Marks M. A., Mathieu J. E., & Zaccaro S. J. (2001). A temporally based framework and taxonomy of team processes. Academy of Management Review, 26(3), 356-376. https://doi.org/10.5465/amr.2001.4845785
doi: 10.2307/259182 URL |
| [81] |
Mayer R. C., Davis J. H., & Schoorman F. D. (1995). An integrative model of organizational trust. Academy of Management Review, 20(3), 709-734. https://doi.org/10.5465/amr.1995.9508080335
doi: 10.2307/258792 URL |
| [82] | McAllister D. J. (1995). Affect- and cognition-based trust as foundations for interpersonal cooperation in organizations. Journal of The Academy of Management, 38(1), 24-59. |
| [83] |
McDonnell M., & Baxter D. (2019). Chatbots and gender stereotyping. Interacting with Computers, 31(2), 116-121. https://doi.org/10.1093/iwc/iwz007
doi: 10.1093/iwc/iwz007 URL |
| [84] | Mizumaru K., Satake S., Kanda T., & Ono T. (2019). Stop doing it! Approaching strategy for a robot to admonish pedestrians. In 2019 14th ACM/IEEE International Conference on Human-Robot Interaction (HRI) (pp.449-457). Daegu, Korea (South). https://doi.org/10.1109/HRI.2019.8673017 |
| [85] |
Mou Y., & Xu K. (2017). The media inequality: Comparing the initial human-human and human-AI social interactions. Computers in Human Behavior, 72, 432-440. https://doi.org/10/gf2k3r
doi: 10.1016/j.chb.2017.02.067 URL |
| [86] |
Narzary S., Makhecha U. P., Budhwar P., Malik A., & Kumar S. (2024). A temporal evolution of human resource management and technology research: A retrospective bibliometric analysis. Personnel Review, 54(3), 800-823. https://doi.org/10.1108/PR-04-2023-0296
doi: 10.1108/PR-04-2023-0296 URL |
| [87] |
Nicholson C. Y., Compeau L. D., & Sethi R. (2001). The role of interpersonal liking in building trust in long-term channel relationships. Journal of the Academy of Marketing Science, 29(1), 3-15. https://doi.org/10.1177/0092070301291001
doi: 10.1177/0092070301291001 URL |
| [88] |
O’Neill T., McNeese N., Barron A., & Schelble B. (2022). Human-autonomy teaming: A review and analysis of the empirical literature. Human Factors, 64(5), 904-938. https://doi.org/10.1177/0018720820960865
doi: 10.1177/0018720820960865 URL |
| [89] | Ososky S., Schuster D., Phillips E., & Jentsch F. G. (2013). Building appropriate trust in human-robot teams. In AAAI Spring Symposium: Trust and Autonomous Systems (pp. 60-65), California, United States. |
| [90] |
Ozaras G., & Abaan S. (2018). Investigation of the trust status of the nurse-patient relationship. Nursing Ethics, 25(5), 628-639. https:// doi.org/10.1177/0969733016664971
doi: 10.1177/0969733016664971 URL pmid: 27605556 |
| [91] | Paetzel M., Perugia G., & Castellano G. (2020). The persistence of first impressions: The effect of repeated interactions on the perception of a social robot. In Proceedings of the 2020 ACM/IEEE International Conference on Human-Robot Interaction (pp.73-82). Cambridge, United Kingdom. https://doi.org/10.1145/3319502.3374786 |
| [92] |
Pereira V., Hadjielias E., Christofi M., & Vrontis D. (2023). A systematic literature review on the impact of artificial intelligence on workplace outcomes: A multi-process perspective. Human Resource Management Review, 33(1), 100857. https://doi.org/10.1016/j.hrmr.2021.100857
doi: 10.1016/j.hrmr.2021.100857 URL |
| [93] |
Podsakoff P. M., Bommer W. H., Podsakoff N. P., & MacKenzie S. B. (2006). Relationships between leader reward and punishment behavior and subordinate attitudes, perceptions, and behaviors: A meta-analytic review of existing and new research. Organizational Behavior and Human Decision Processes, 99(2), 113-142. https:// doi.org/10.1016/j.obhdp.2005.09.002
doi: 10.1016/j.obhdp.2005.09.002 URL |
| [94] |
Qi Y., Chen J. T., Qin S. T., & Du F. (2024). Human-AI mutual trust in the era of artificial general intelligence. Advances in Psychological Science, 32(12), 2124-2136. https://doi.org/10.3724/SP.J.1042.2024.001
doi: 10.3724/SP.J.1042.2024.02124 URL |
| [95] |
Raisch S., & Krakowski S. (2021). Artificial intelligence and management: The automation-augmentation paradox. Academy of Management Review, 46(1), 192-210. https://doi.org/10.5465/amr.2018.0072
doi: 10.5465/amr.2018.0072 URL |
| [96] |
Raver J. L., Jensen J. M., Lee J., & O’Reilly J. (2012). Destructive criticism revisited: Appraisals, task outcomes, and the moderating role of competitiveness. Applied Psychology, 61(2), 177-203. https://doi.org/10.1111/j.1464-0597.2011.00462.x
doi: 10.1111/apps.2012.61.issue-2 URL |
| [97] |
Robinette P., Howard A. M., & Wagner A. R. (2017). Effect of robot performance on human-robot trust in time-critical situations. IEEE Transactions on Human-Machine Systems, 47(4), 425-436. https:// doi.org/10.1109/THMS.2017.2648849
doi: 10.1109/THMS.2017.2648849 URL |
| [98] |
Roesler E., Vollmann M., Manzey D., & Onnasch L. (2024). The dynamics of human-robot trust attitude and behavior—Exploring the effects of anthropomorphism and type of failure. Computers in Human Behavior, 150, 108008. https://doi.org/10.1016/j.chb.2023.108008
doi: 10.1016/j.chb.2023.108008 URL |
| [99] |
Rosén J., Lindblom J., Lamb M., & Billing E. (2024). Previous experience matters: An in-person investigation of expectations in human-robot interaction. International Journal of Social Robotics, 16(3), 447-460. https://doi.org/10.1007/s12369-024-01107-3
doi: 10.1007/s12369-024-01107-3 URL |
| [100] |
Rozin P., & Royzman E. B. (2001). Negativity bias, negativity dominance, and contagion. Personality and Social Psychology Review, 5(4), 296-320. https://doi.org/10.1207/S15327957PSPR0504_2
doi: 10.1207/S15327957PSPR0504_2 URL |
| [101] |
Sanders T., Kaplan A., Koch R., Schwartz M., & Hancock P. A. (2019). The relationship between trust and use choice in human- robot interaction. Human Factors, 61(4), 614-626. https://doi.org/10.1177/0018720818816838
doi: 10.1177/0018720818816838 URL pmid: 30601683 |
| [102] |
Skowronski J. J., & Carlston D. E. (1989). Negativity and extremity biases in impression formation: A review of explanations. Psychological Bulletin, 105(1), 131-142. https://doi.org/10.1037/0033-2909.105.1.131
doi: 10.1037/0033-2909.105.1.131 URL |
| [103] | Skubis I., & Wodarski K. (2023). Humanoid robots in managerial positions-decision-making process and human oversight. Scientific Papers of Silesian University of Technology. Organization and Management Series, 2023(189), 573-596. https://doi.org/10.29119/1641-3466.2023.189.36 |
| [104] |
Srull T. K., & Wyer R. S. (1989). Person memory and judgment. Psychological Review, 96(1), 58-83. https://doi.org/10.1037/0033-295X.96.1.58
URL pmid: 2648446 |
| [105] |
Tonidandel S., Quiñones M. A., & Adams A. A. (2002). Computer- adaptive testing: The impact of test characteristics on perceived performance and test takers' reactions. Journal of Applied Psychology, 87(2), 320-332. https://doi.org/10.1037/0021-9010.87.2.320
URL pmid: 12002960 |
| [106] |
Ulfert A.-S., Georganta E., Centeio Jorge C., Mehrotra S., & Tielman M. (2024). Shaping a multidisciplinary understanding of team trust in human-AI teams: A theoretical framework. European Journal of Work and Organizational Psychology, 33(2), 158-171. https://doi.org/10.1080/1359432X.2023.2200172
doi: 10.1080/1359432X.2023.2200172 URL |
| [107] | Van der Hoorn D. P. M., Neerincx A., & de Graaf M. M. A. (2021). "I think you are doing a bad job!": The effect of blame attribution by a robot in human-robot collaboration. In Proceedings of the 2021 ACM/IEEE International Conference on Human-Robot Interaction (pp.140-148). Boulder, United States. https://doi.org/10/gjgptk |
| [108] |
Van Dongen K., & Van Maanen P.-P. (2013). A framework for explaining reliance on decision aids. International Journal of Human-Computer Studies, 71(4), 410-424. https://doi.org/10.1016/j.ijhcs.2012.10.018
doi: 10.1016/j.ijhcs.2012.10.018 URL |
| [109] |
Van Pinxteren M. M. E., Wetzels R. W. H., Rüger J., Pluymaekers M., & Wetzels M. (2019). Trust in humanoid robots: Implications for services marketing. Journal of Services Marketing, 33(4), 507-518. https://doi.org/10.1108/JSM-01-2018-0045
doi: 10.1108/JSM-01-2018-0045 URL |
| [110] | Vance A., Elie-Dit-Cosaque C., & Straub D. W. (2008). Examining trust in information technology artifacts: The effects of system quality and culture. Journal of Management Information Systems, 24(4), 73-100. https://doi.org/10.2753/MIS0742-1222240403 |
| [111] |
Vanneste B. S., & Puranam P. (2024). Artificial intelligence, trust, and perceptions of agency. Academy of Management Review, 50(4), 726-744. https://doi.org/10.5465/amr.2022.0041
doi: 10.5465/amr.2022.0041 URL |
| [112] |
Von Krogh G. (2018). Artificial intelligence in organizations: New opportunities for phenomenon-based theorizing. Academy of Management Discoveries, 4(4), 404-409. https://doi.org/10.5465/amd.2018.0084
doi: 10.5465/amd.2018.0084 URL |
| [113] |
Walter N., Ortbach K., & Niehaves B. (2015). Designing electronic feedback - analyzing the effects of social presence on perceived feedback usefulness. International Journal of Human-Computer Studies, 76, 1-11. https://doi.org/10.1016/j.ijhcs.2014.12.001
doi: 10.1016/j.ijhcs.2014.12.001 URL |
| [114] |
Watts S. A. (2007). Evaluative feedback: Perspectives on media effects. Journal of Computer-Mediated Communication, 12(2), 384-411. https://doi.org/10.1111/j.1083-6101.2007.00330.x
doi: 10.1111/jcmc.2007.12.issue-2 URL |
| [115] |
Weiss H. M., Suckow K., & Cropanzano R. (1999). Effects of justice conditions on discrete emotions. Journal of Applied Psychology, 84(5), 786-794. https://doi.org/10/dp7s56
doi: 10.1037/0021-9010.84.5.786 URL |
| [116] | Whitehair C., & Berdanier C. G. (2017). The role of trust in collaborative research settings:Opportunities for future research in graduate engineering education. 2017 ASEE Annual Conference & Exposition, Columbus, United States. https://doi.org/10.18260/1-2--29008 |
| [117] |
Wynne K. T., & Lyons J. B. (2018). An integrative model of autonomous agent teammate-likeness. Theoretical Issues in Ergonomics Science, 19(3), 353-374. https://doi.org/10/ggxp4d
doi: 10.1080/1463922X.2016.1260181 URL |
| [118] |
Xu L. Y., Yu F., & Peng K. P. (2022). Algorithmic discrimination causes less desire for moral punishment than human discrimination. Acta Psychologica Sinica, 54(9), 1076-1092. https://doi.org/10.3724/SP.J.1041.2022.01076
doi: 10.3724/SP.J.1041.2022.01076 URL |
| [119] | Xu M., David J. M., & Kim S. H. (2018). The fourth industrial revolution: Opportunities and challenges. International Journal of Financial Research, 9(2), 90-95. https://doi.org/10.5430/ijfr.v9n2p90 |
| [120] |
Xuan H., & He G. (2025). Negative feedback from robots is received better than that from humans: The effect of feedback on human-robot trust and collaboration. Journal of Business Research, 193, 115333. https://doi.org/10.1016/j.jbusres.2025.115333
doi: 10.1016/j.jbusres.2025.115333 URL |
| [121] |
Yalcin G., Lim S., Puntoni S., & Van Osselaer, S. M. J.(2022). Thumbs up or down: Consumer reactions to decisions by algorithms versus humans. Journal of Marketing Research, 59(4), 696-717. https://doi.org/10.1177/00222437211070016
doi: 10.1177/00222437211070016 URL |
| [122] |
Yam K. C., Goh E.-Y., Fehr R., Lee R., Soh H., & Gray K. (2022). When your boss is a robot: Workers are more spiteful to robot supervisors that seem more human. Journal of Experimental Social Psychology, 102, 104360. https://doi.org/10.1016/j.jesp.2022.104360
doi: 10.1016/j.jesp.2022.104360 URL |
| [123] |
Yang X. J., Schemanske C., & Searle C. (2023). Toward quantifying trust dynamics: How people adjust their trust after moment-to-moment interaction with automation. Human Factors, 65(5), 862-878. https://doi.org/10.1177/00187208211034716
doi: 10.1177/00187208211034716 URL |
| [124] | You S., Nie J., Suh K., & Sundar S. S. (2011). When the robot criticizes you... Self-serving bias in human-robot interaction. In Proceedings of the 6th International Conference on Human-Robot Interaction (pp. 295-296). Lausanne, Switzerland. https://doi.org/10/b7td8d |
| [1] | WANG Chen, CHEN Weicong, HUANG Liang, HOU Suyu, WANG Yiwen. Robots abide by ethical principles promote human-robot trust? The reverse effect of decision types and the human-robot projection hypothesis [J]. Acta Psychologica Sinica, 2024, 56(2): 194-209. |
| [2] | FAN Wei, REN Mengmeng, ZHANG Wenjie, ZHONG Yiping. The impact of feedback on self-deception: Evidence from ERP [J]. Acta Psychologica Sinica, 2022, 54(5): 481-496. |
| Viewed | ||||||
|
Full text |
|
|||||
|
Abstract |
|
|||||
